Who I am
I am a second-year Master's student in Mechanical Engineering at Carnegie Mellon University. My research in the Robomechanics Lab, advised by Prof. Aaron Johnson, involves simulating quadrupeds in different environments, deploying policies and running hardware experiments, and designing robust learned controllers over complex, contact-rich natural environments.
Prior to CMU, I earned my Bachelors of Engineering in Mechanical Engineering from Stevens institute of Technology, where I worked in the PROOF Lab under Prof. Kishore Pochiraju designing algorithms for manipulation tasks. I'm originally from Queens, NYC and am currently based in Pittsburgh.

Recent news
-
Sep 2026
I attended the MaGIC 2026 (Machine-Ground Interaction Consortium) conference, where I presented a poster on my research on reduced order modeling for locomotion through deep mud. Conference Link

-
May 2026
I met Jensen Huang, the founder and CEO of NVIDIA, at Carnegie Mellon's pre-commencement and had the opportunity to share how I am utilizing Nvidia Omniverse in my research. CMU News

-
May 2026
My research on training adaptive policies for quadruped robots to traverse muddy terrain, conducted in collaboration with FieldAI, was featured in a CMU Engineering article. CMU Engineering

Selected projects
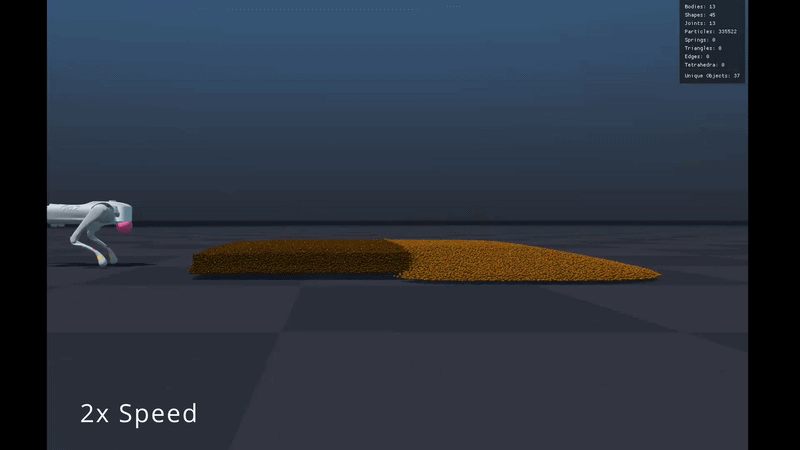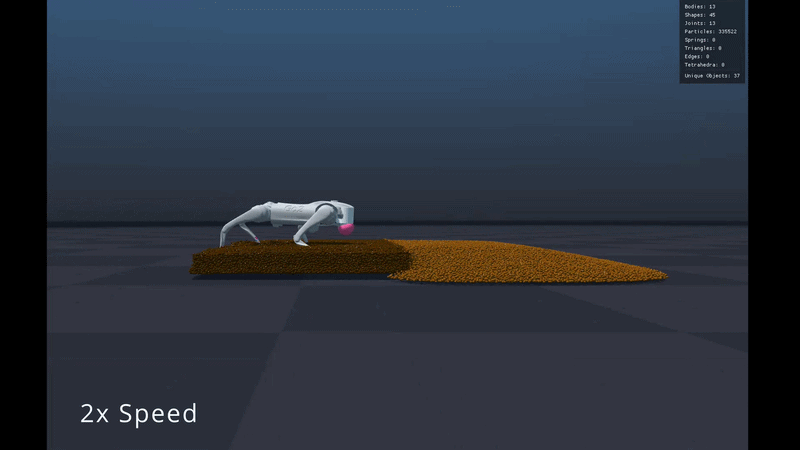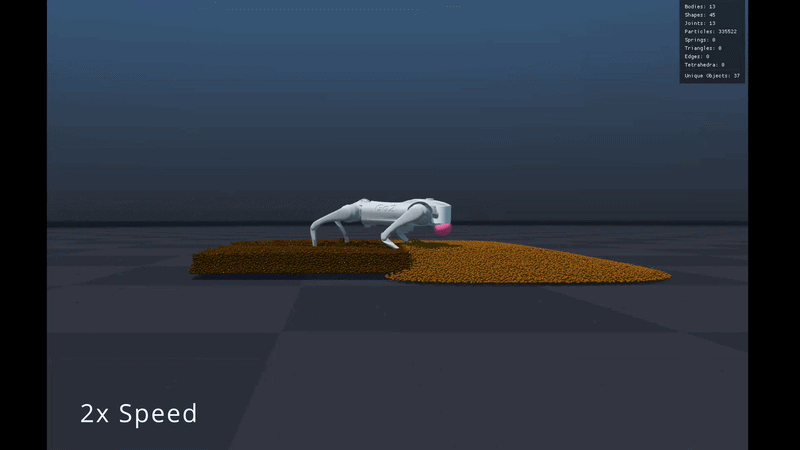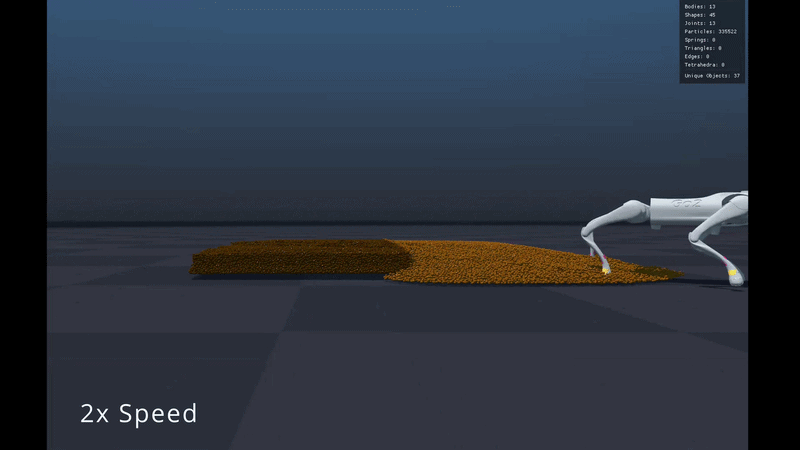
Quadruped Locomotion Through Mud
Reduced-order models of mud forces and learned controllers for mud-adaptive locomotion, with FieldAI.
Quad-SDK: MuJoCo Integration
MuJoCo support for Quad-SDK's ROS2 control stack, plus Python tools for analyzing hardware runs.
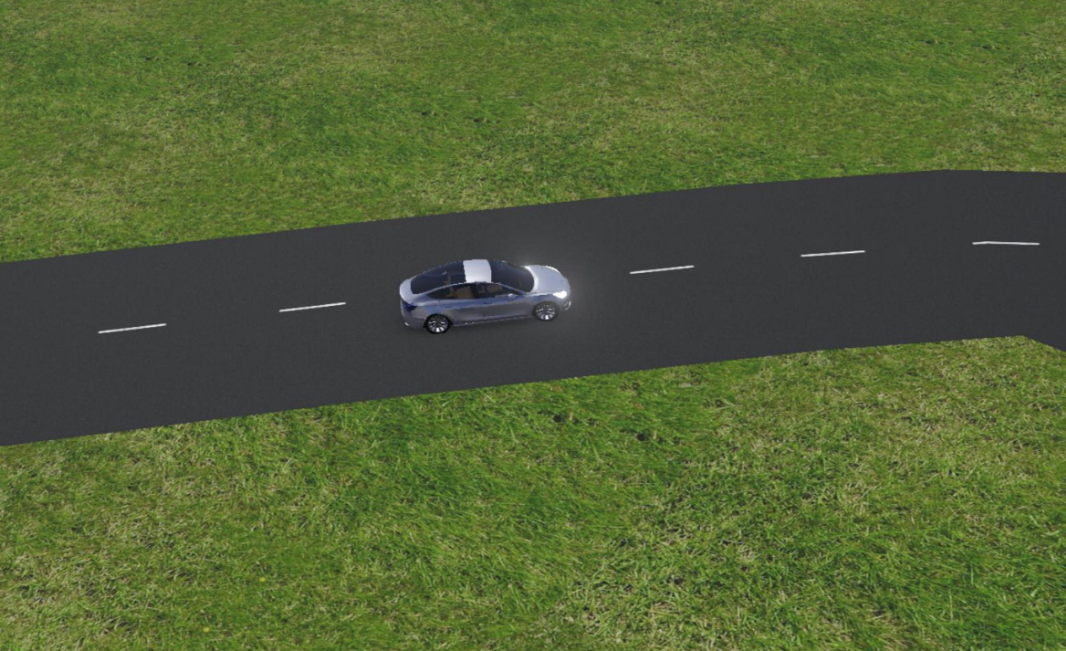
SLAM and FSD for a Tesla Model 3
PID, LQR and MPC controllers compared in Webots, with A* replanning and EKF SLAM.
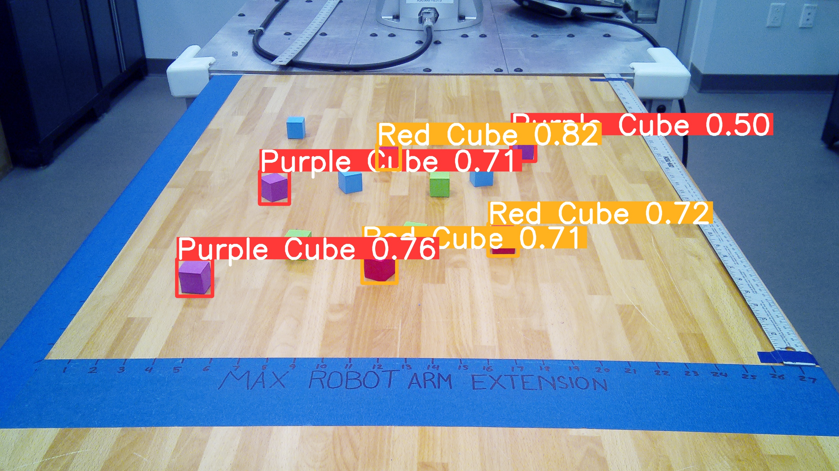
Pick and Place Camera Algorithm
YOLOv8 model driving a Doosan H2515 arm over a TCP client-server link.
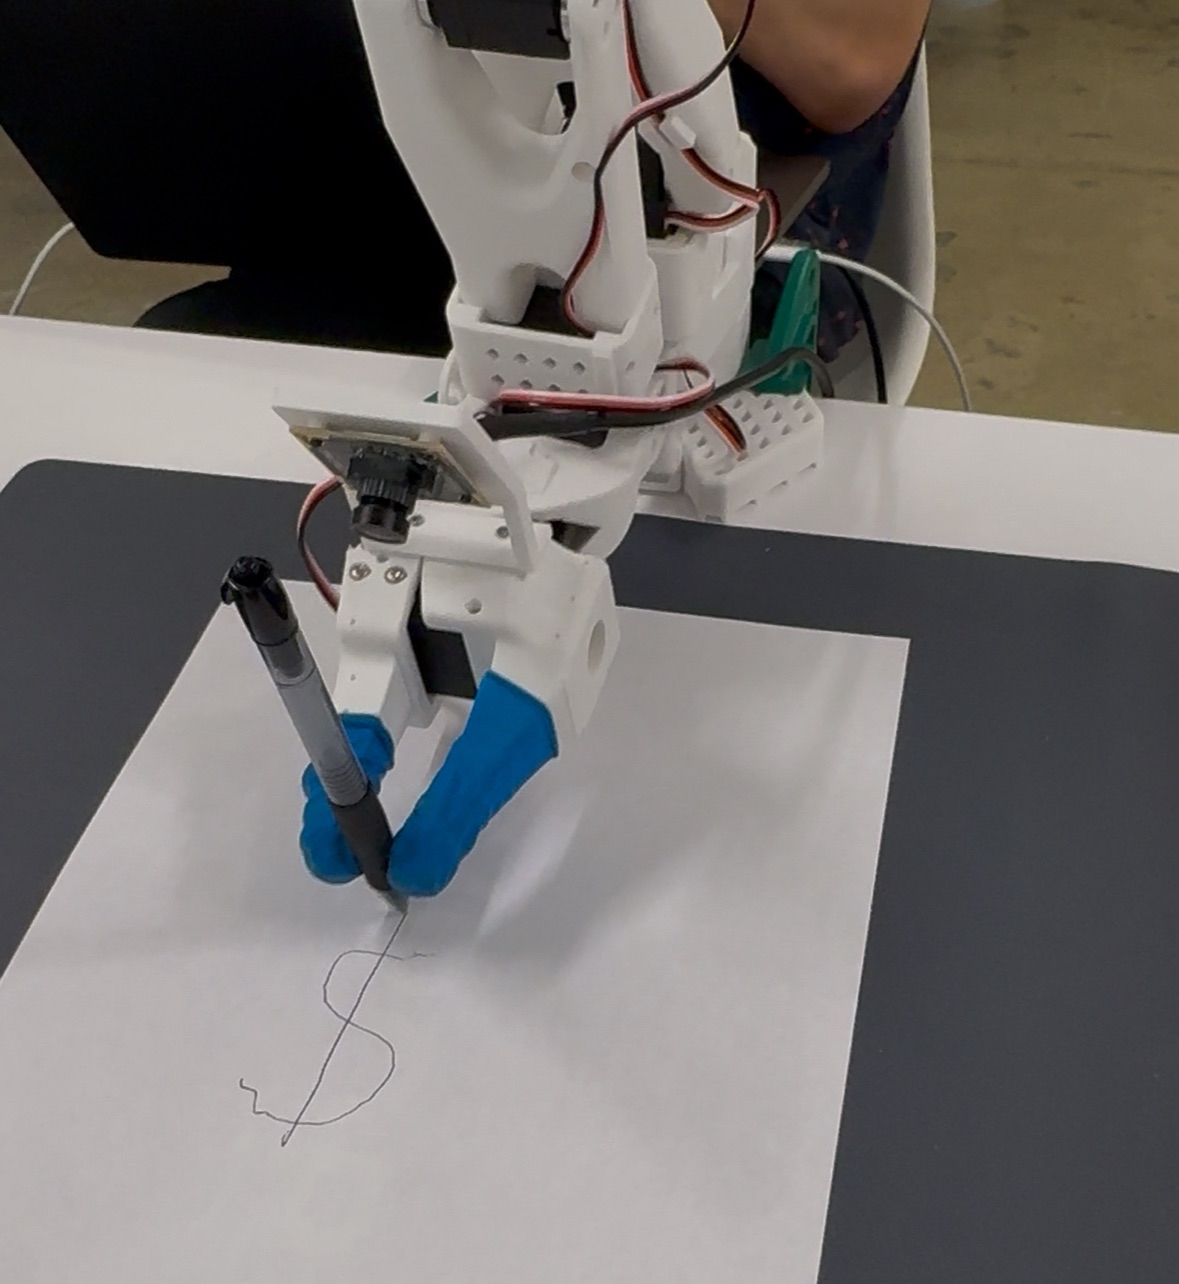
LeRobot Hackathon — SO-100
Filtering and frame skipping doubled task speed. Won Most Innovative Use of Data.
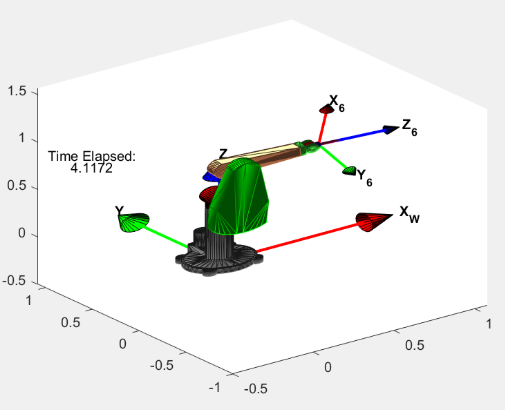
Resolved Rates and Manipulation
Null-space projection and min-norm pseudoinverse redundancy resolution in MATLAB.